CV / Google Scholar / GitHub
I am currently an Assistant Professor in the Neuro-Robotics Lab at Tohoku University. I received my Ph.D. in Robotics from Tohoku University (early completion, one year ahead of schedule) under the supervision of Prof. Mitsuhiro Hayashibe, and was honored with the Tohoku University Professor Fujino Incentive Award.
I am also a core researcher in the Neuro-Humanoid Project of Japan's Moonshot R&D Program.
Before joining academia, I worked for about ten years as an engineer in technology and quality roles in the automotive and machinery industries.
My research interests include embodied AI, robotic manipulation, multimodal learning in robotics, deformable object manipulation, LLMs in robotics, and the industrial applications of robotics.
My long-term goal is to enable human-like perception and manipulation in robots to contribute to a better world.
Email: gu.ningquan.c3@dc.tohoku.ac.jp
Office: 503, Mechanical and Aerospace Eng. Research Building (A15), Aoba-ku Sendai, Japan.
Updates
- November 2026 Our paper "Do Robots Need All Tactile Signals? Evaluating Tactile Field Selection in Contact-rich Imitation Learning" (with Tao Liu and Mitsuhiro Hayashibe) was accepted to IEEE/SICE SII 2027.
- October 2026 I joined the Neuro-Robotics Lab at Tohoku University as an Assistant Professor.
- September 25, 2026 I received my Ph.D. from Tohoku University and was honored with the Tohoku University Professor Fujino Incentive Award.
Publications
Ningquan Gu; Yuquan Li; Kazuhiro Kosuge; Mitsuhiro Hayashibe
IEEE Robotics and Automation Letters 2026
Webpage •
Paper
Ningquan Gu; Kazuhiro Kosuge; Mitsuhiro Hayashibe
IEEE Robotics and Automation Letters 2025
Webpage •
Paper •
Ningquan Gu; Ruhan He; Lianqing Yu
IEEE Robotics and Automation Letters 2024
Webpage •
Paper •
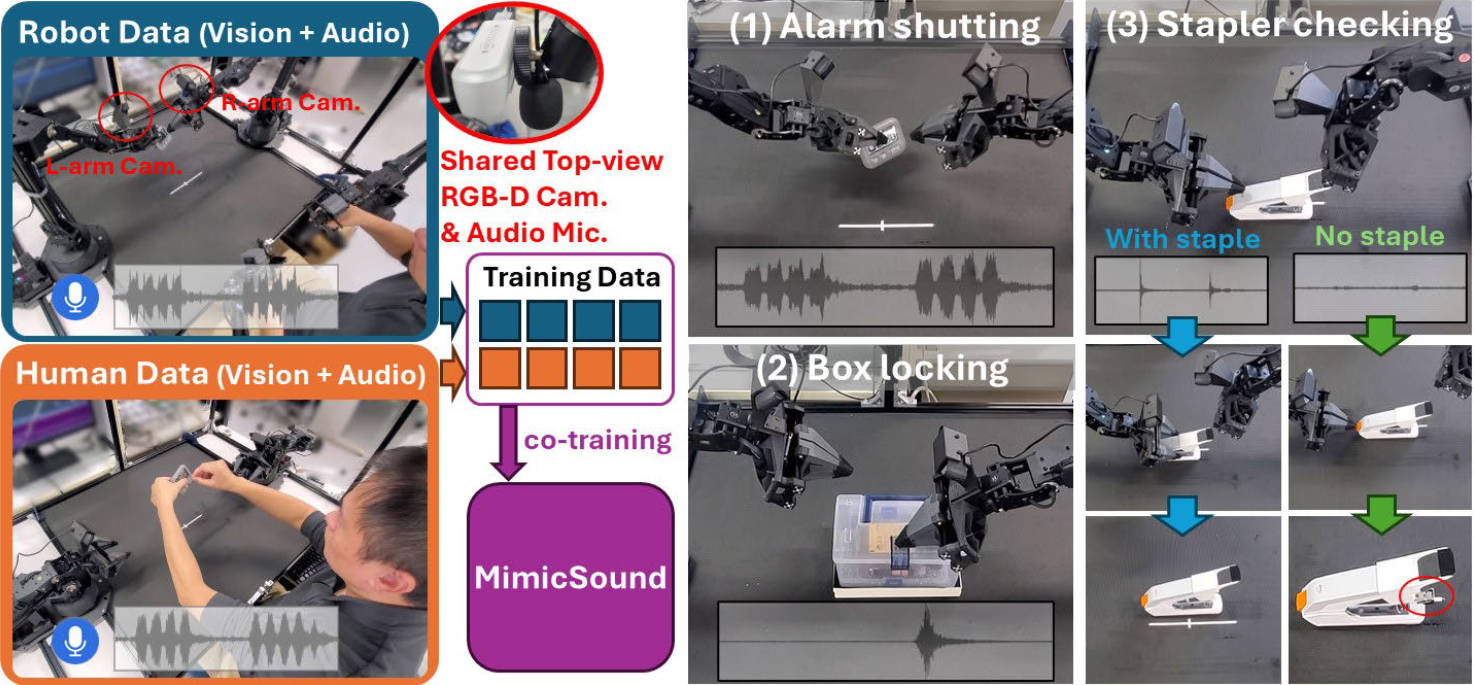 MimicSound: Learning Bimanual Manipulation from Audio-Visual Human Videos
Ningquan Gu; Kazuhiro Kosuge; Mitsuhiro Hayashibe
IEEE Access 2026
Webpage •
Paper
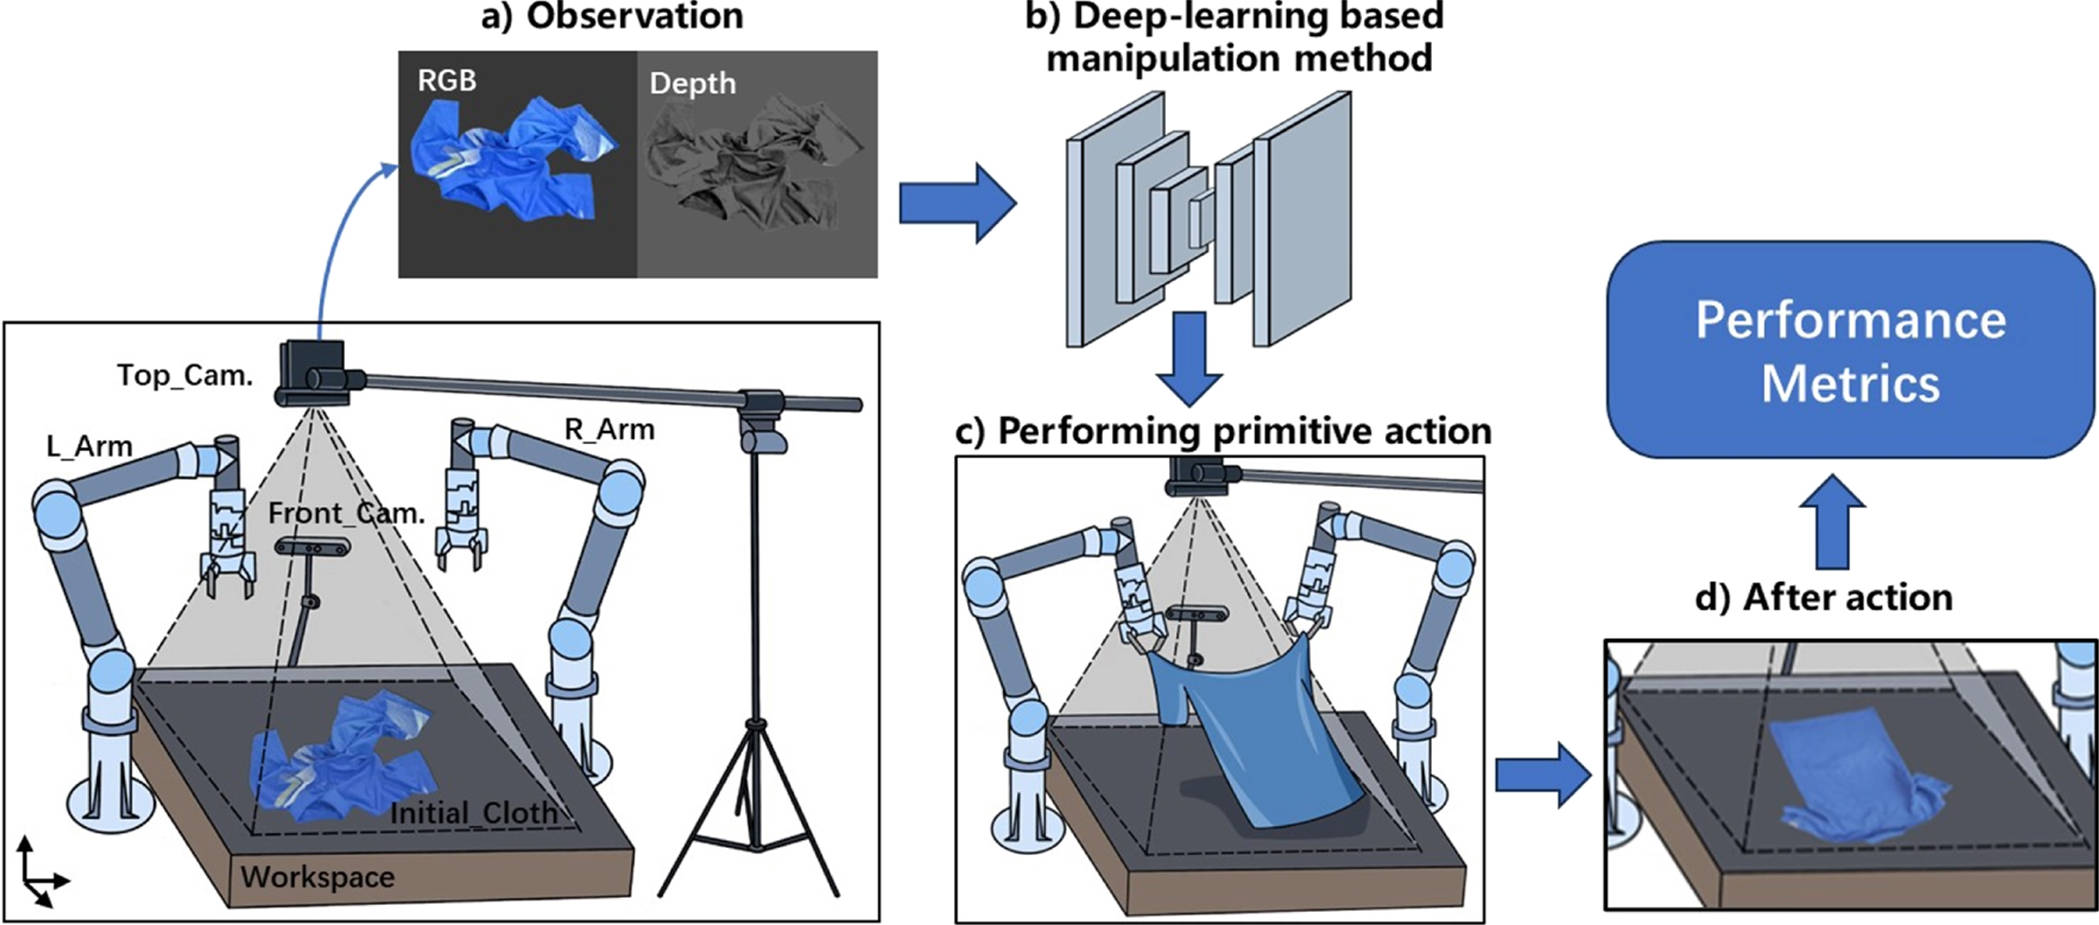 Deep learning-based robotic cloth manipulation applications: systematic review, challenges and opportunities for physical AI
Ningquan Gu; Mitsuhiro Hayashibe; Kyo Kutsuzawa; Hui Yu
Frontiers in Robotics and AI 2026
Paper
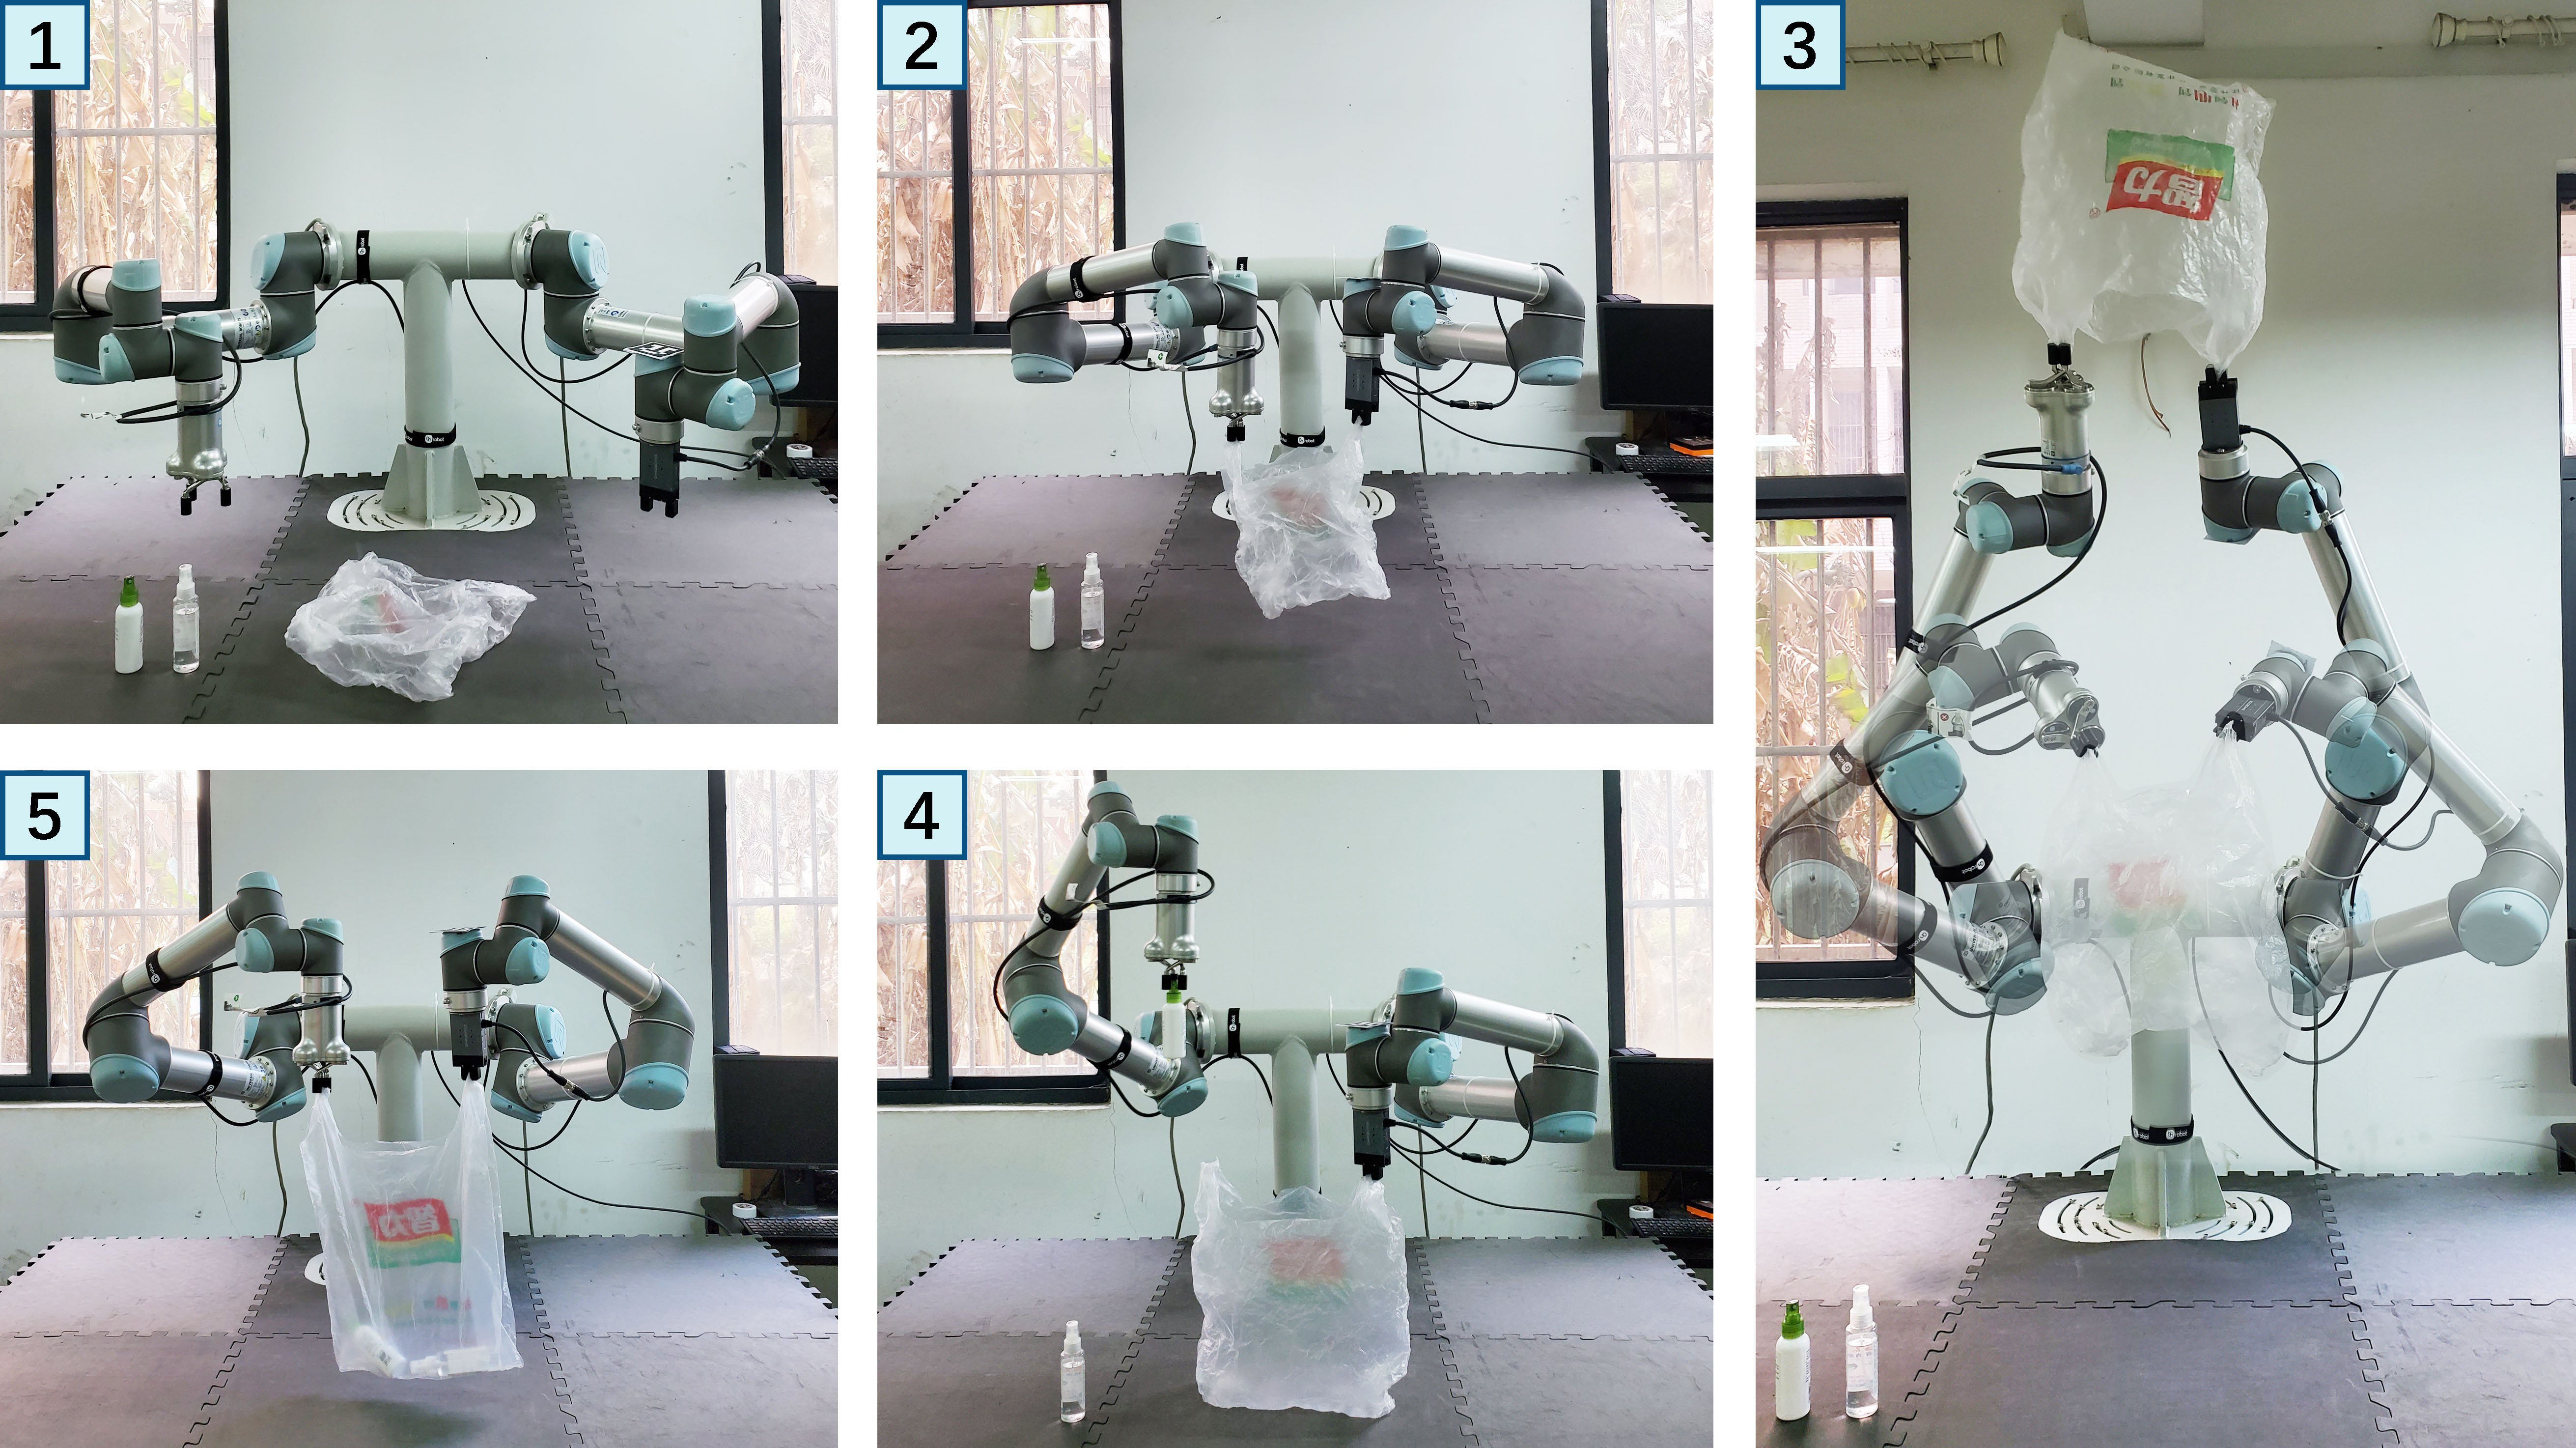 ShakingBot: Dynamic Manipulation for Bagging
Ningquan Gu; Zhizhong Zhang; Ruhan He; Lianqing Yu
Robotica (Cover Article) 2024
Paper •
Honors & Awards
- Tohoku University Professor Fujino Incentive Award (東北大学藤野先生記念奨励賞), 2026
- Cover Article, Robotica, 2024 ("ShakingBot: Dynamic Manipulation for Bagging")
- Two First Prizes (Humanoid Robot Sprint; Penalty Kick), China Robotics and AI Competition (CAAI), 2022
Patents
- N. Gu, R. He, "A dual-arm humanoid intelligent folding robot," Chinese Invention Patent ZL 2023 1 0557628.0, granted Jan. 2024.
- N. Gu, R. He, "Ultraviolet-based high-precision keypoint detection method and application for textiles," Chinese Invention Patent ZL 2023 1 0617337.6, granted Jul. 2025.
Academic Service
- Reviewer: IEEE Robotics and Automation Letters (RA-L); IEEE/RSJ IROS 2026, 2027; IEEE/SICE SII 2027